 ofxAddons

OpenFrameworks addon for working with image streams from remote depth sensor
Forks
Forks pushed to more recently than fusefactory/ofxDepthStream itself, plus any admin-confirmed fork with commits of its own — worth checking if you're hitting issues with the original.

Branches ahead of master
These branches have commits not yet on master — could be unmerged fixes or work in progress worth a look.
README
ofxDepthStream
OpenFrameworks addon with _heavily opiniated_ tools for working with remote Depth Sensor streams.
What?
This is a suit of tools to work with multiple (different) depth sensors like the Kinect, the Orbbecs (Persee, Astra and Astra-mini) and -soon- the Intel RealSense.
# What about OpenNI??
OpenNI provides a uniform API for working with various depth sensors and is used in some of the applications in this repository. The aim of this package is to provide high-level tools and instructions to work with remote depth sensors streaming over a network (currently using TCP).
Instructions
Build and run a remote Server
See the ``./tools` folder for various server (transmitter) applications for various platforms/sensors. Each tool has its own README; KinectForWindows2 OrbbecAstraTransmitter OrbbecPerseeTransmitter
Build and run a local Client
This OpenFrameworks addon tailors only to streaming _clients_ (receivers), try any of the example applications:
`cd` into one of the example application's folders and run: make Debug # to build the applications
make RunDebug # to run the last development-build
SDK Usage
See also the API (doxygen) documentation
Basic Usage
See also the example applications
`c++ include "ofxDepthStream/ofxDepthStream.h"
std::shared_ptr<depth::Receiver> receiverRef; ofTexture depthTexture; ofMesh mesh1;
void ofApp::setup() { // Create depth stream network receiver (takes a hostname/ip string and port number) // this receiver instance will start a separate thread in which it listens for new frame data receiverRef = depth::Receiver::createAndStart("persee.local", 4445); }
void ofApp::update() { // this addons provides some convenience methods for; // ...processing raw frame byte data (which is compressed for network streaming) depth::emptyAndInflateBuffer(receiverRef, [this](const void* data, size_t size){
// ...loading texture data ofxDepthStream::loadDepthTexture(this->depthTexture, data, size);
// ...loading mesh data ofxDepthStream::loadMesh(this->mesh1, data, size); } }
void ofApp::draw() { if(depthTexture.isAllocated()) { depthTexture.draw(0,0); }
mesh1.draw(); }
#### Run unit tests
From this addon's root folder;
shell cd tests make Debug make RunDebug ``Screenshots
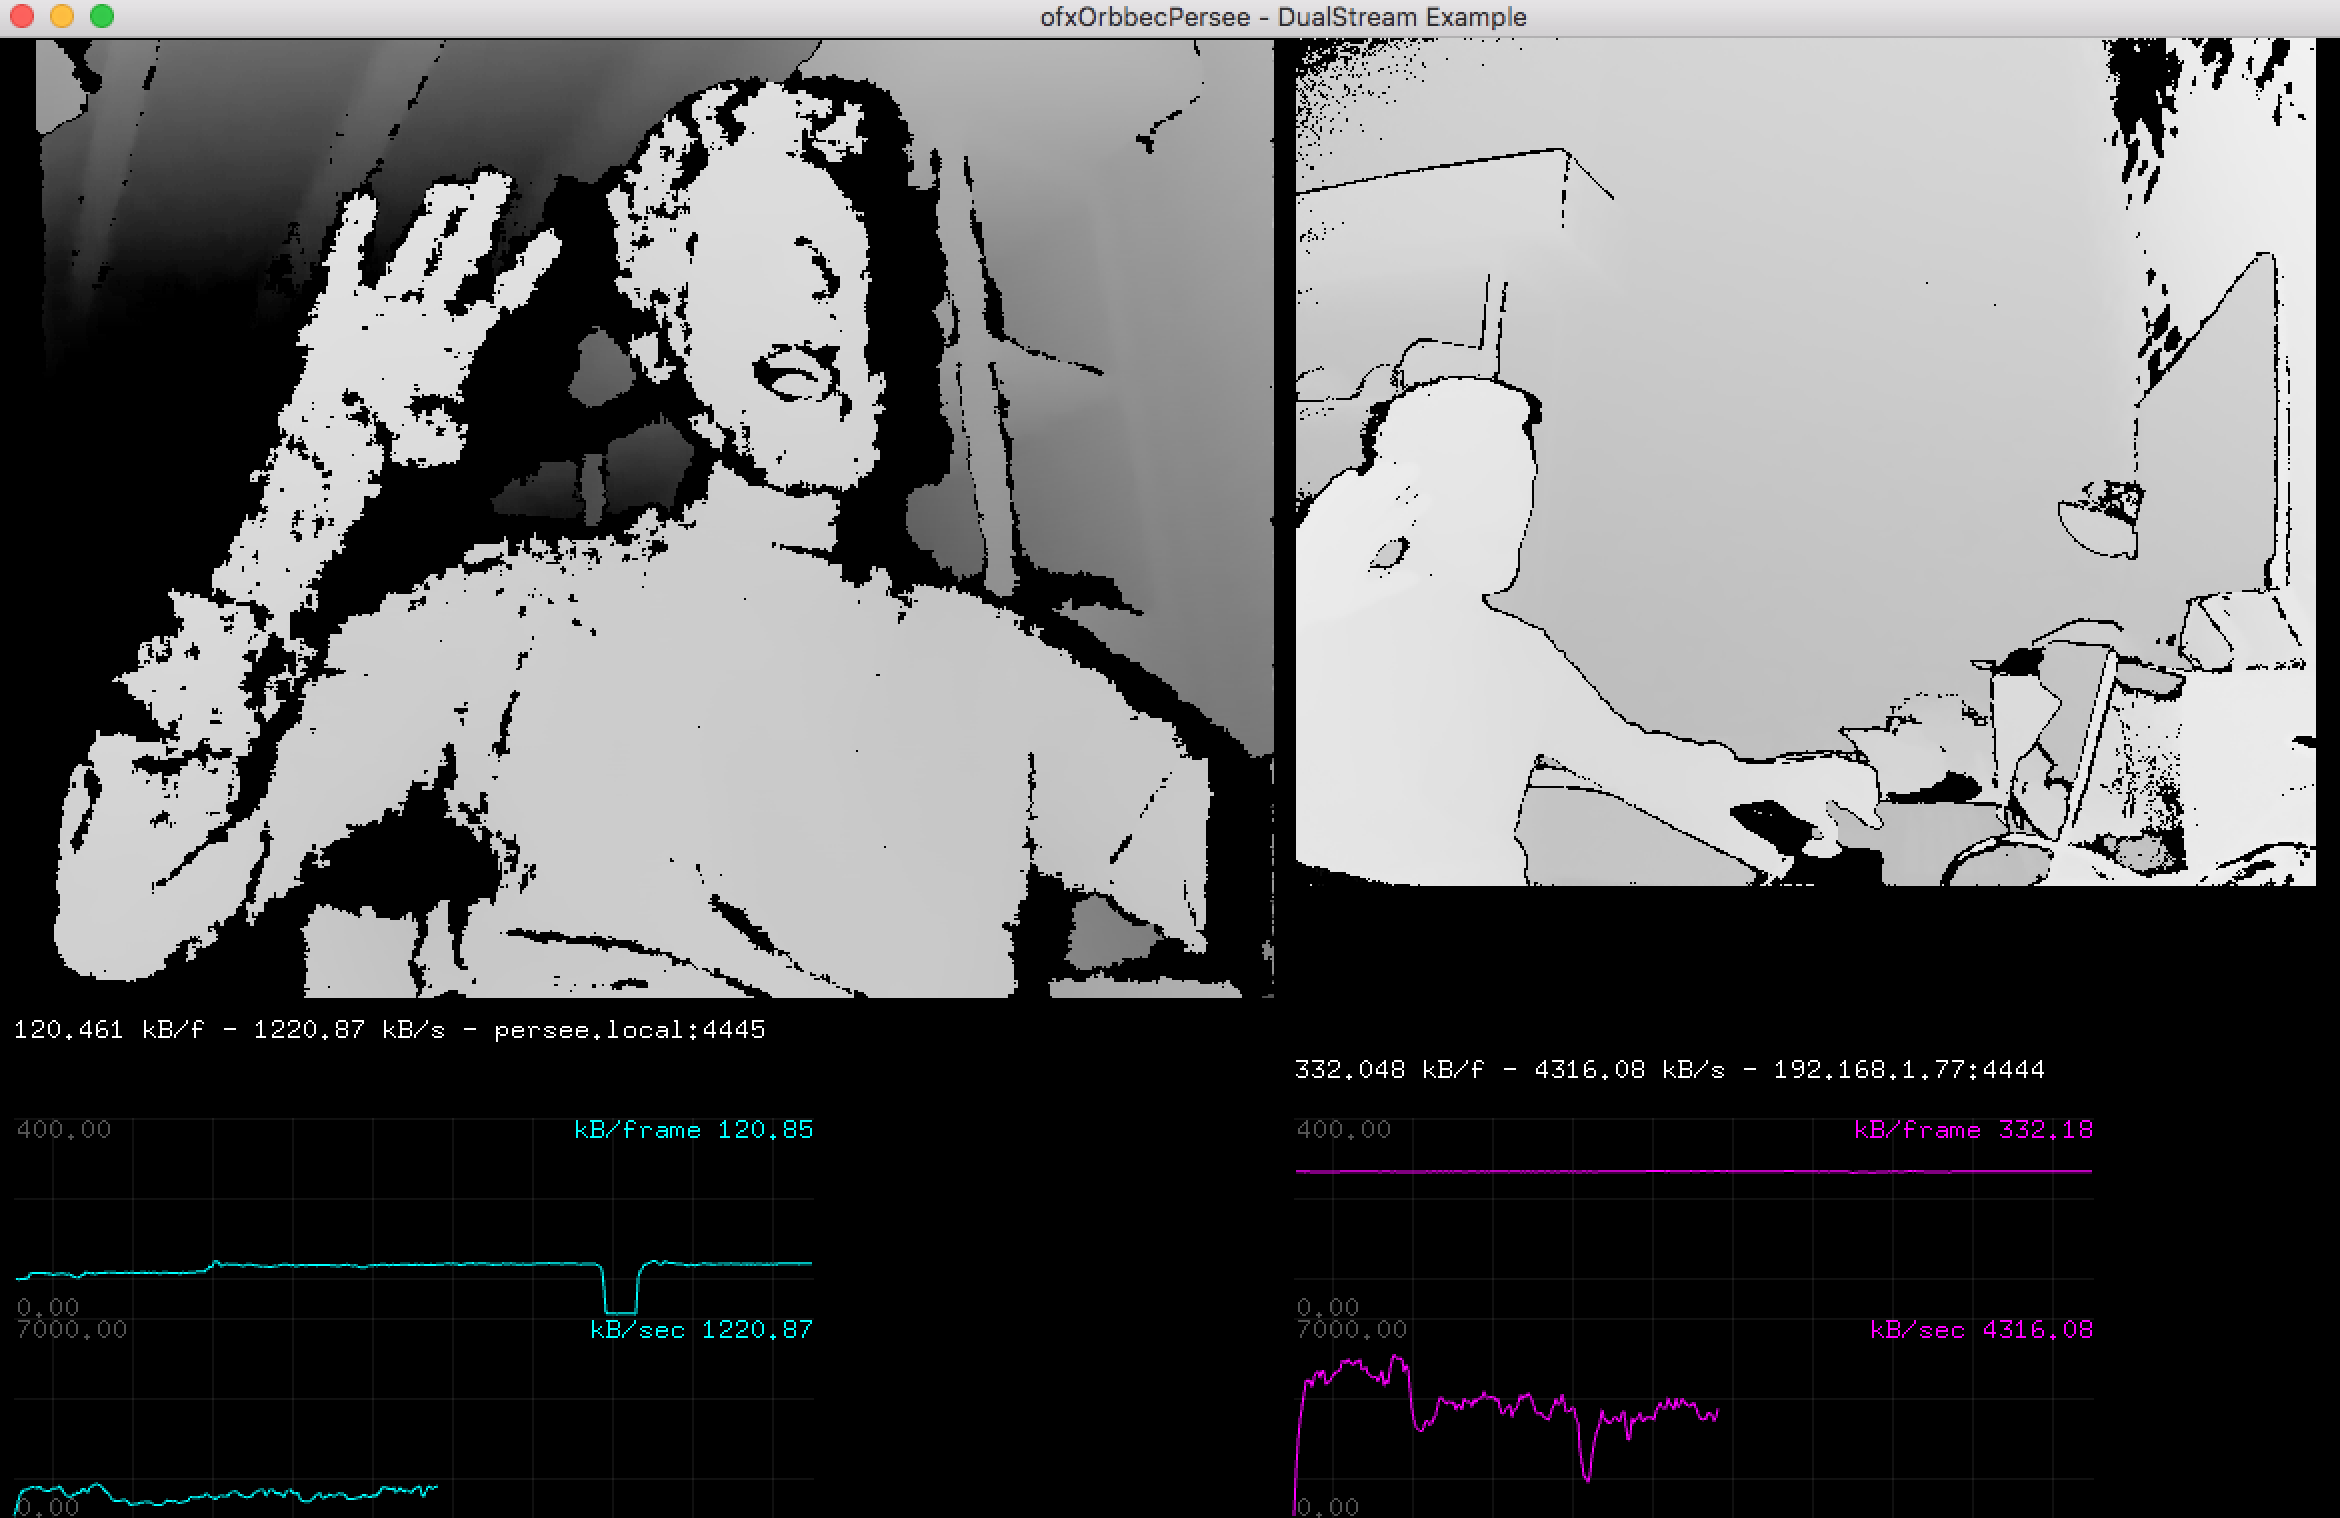 _streaming two sensors over a network; orbbec left, kinect right_